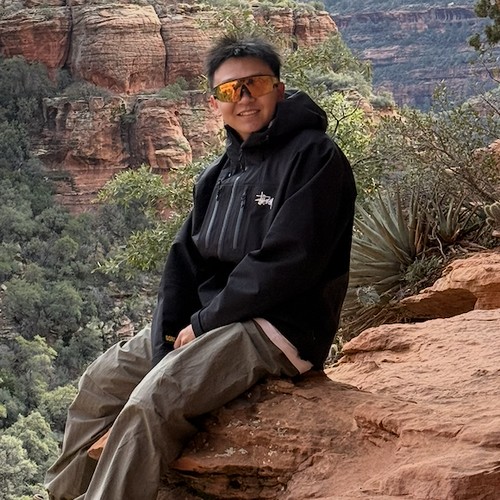
I’m a Ph.D. candidate in Mechanical Engineering at Stevens Institute of Technology, advised by Brendan Englot in the Robust Field Autonomy Lab. Before Stevens, I received my Master’s degree from NYU, advised by Chen Feng in the AI4CE Lab, and my Bachelor’s degree from the Qiushi Honors College at Tianjin University.
I’m interested in robot localization and perception algorithms. Currently, I’m working Multimodal SLAM, sensor fusion and 3D perception for autonomous robotics. I also have extensive deployment experience on ground, aerial, and surface vehicles with cameras, IMUs, LiDAR and GNSS.
News
- 2026.06 Joined the General Motors Autonomous Robotics Center as a Ph.D. intern
- 2026.06 Our paper SGM-SLAM was accepted to SSRR 2026 Main Conference.
- 2026.06 Our paper Reinforcement Learning Based Heterogeneous Task Allocation under Spatio-Temporal Environmental Uncertainty for Multi-Robot Teams was accepted to SSRR 2026 Main Conference.
- 2026.06 Our paper AoII-Based Persistent Monitoring for Unmanned Surface Vehicles in Spatiotemporal Fields was accepted to SSRR 2026 Main Conference.
- 2025.06 Our paper Above and Below: Heterogeneous Multi-robot SLAM Across Surface and Underwater Domains was accepted to RA-L.
- 2025.06 Our paper CVD-SfM was accepted to IROS 2025 Main Conference.
Publications
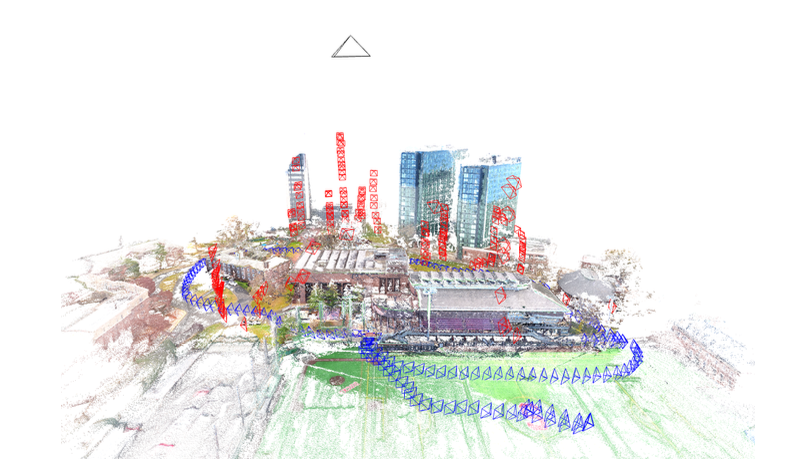
CVD-SfM: A Cross-View Deep Front-end Structure-from-Motion System for Sparse Localization in Multi-Altitude Scenes IROS
Yaxuan Li, Yewei Huang, Bijay Gaudel, Hamidreza Jafarnejadsani, Brendan Englot
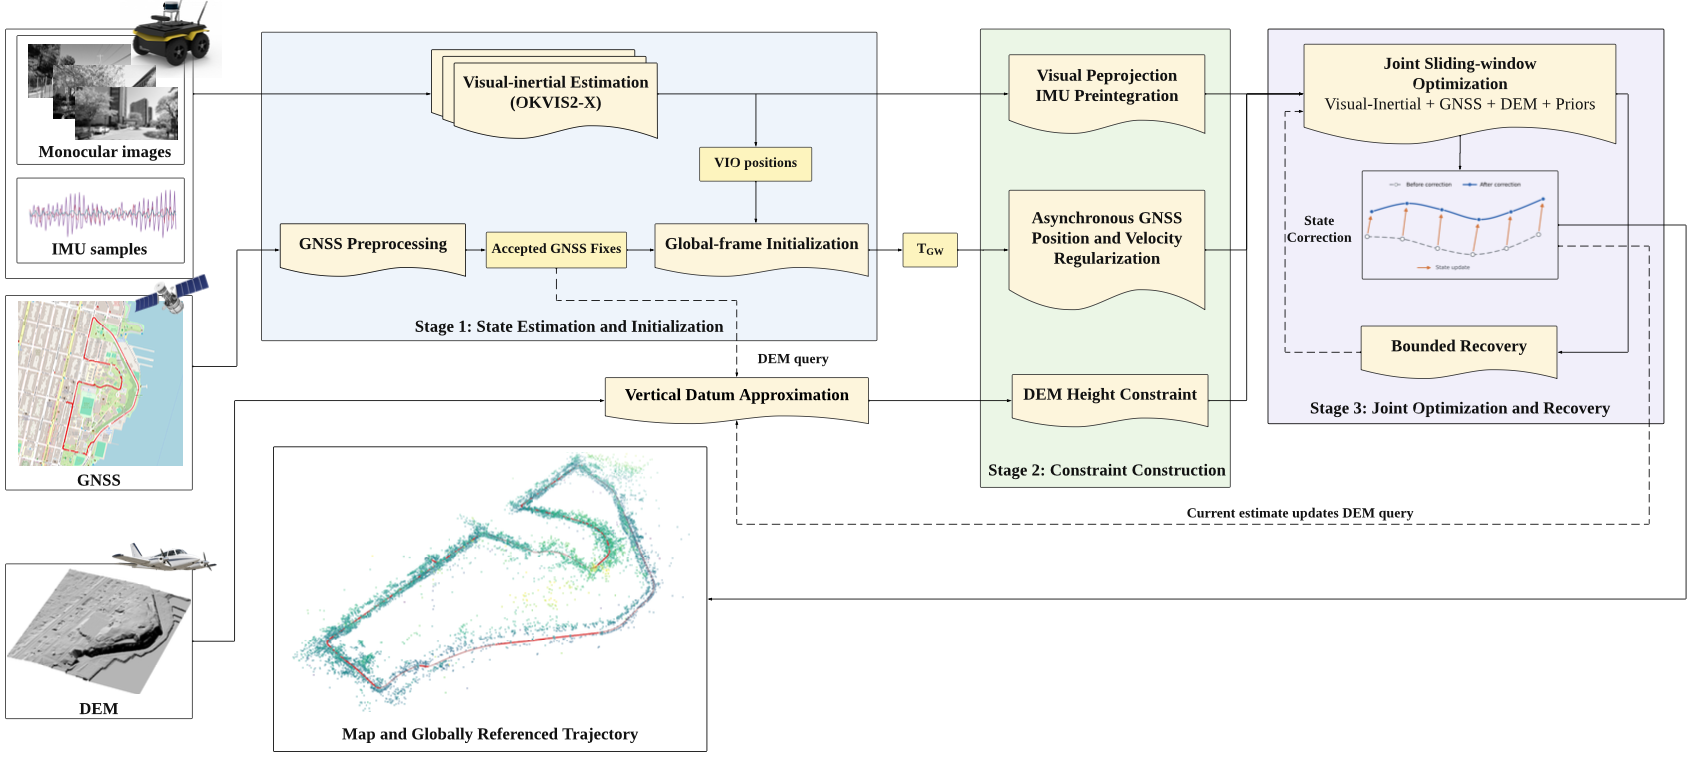
DGVI-SLAM: DEM-Aided Visual–Inertial SLAM with Bounded Position-Fix GNSS Recovery in Variable-Elevation Urban Environments arXiv
Yaxuan Li, Yewei Huang, Xi Lin, Brendan Englot
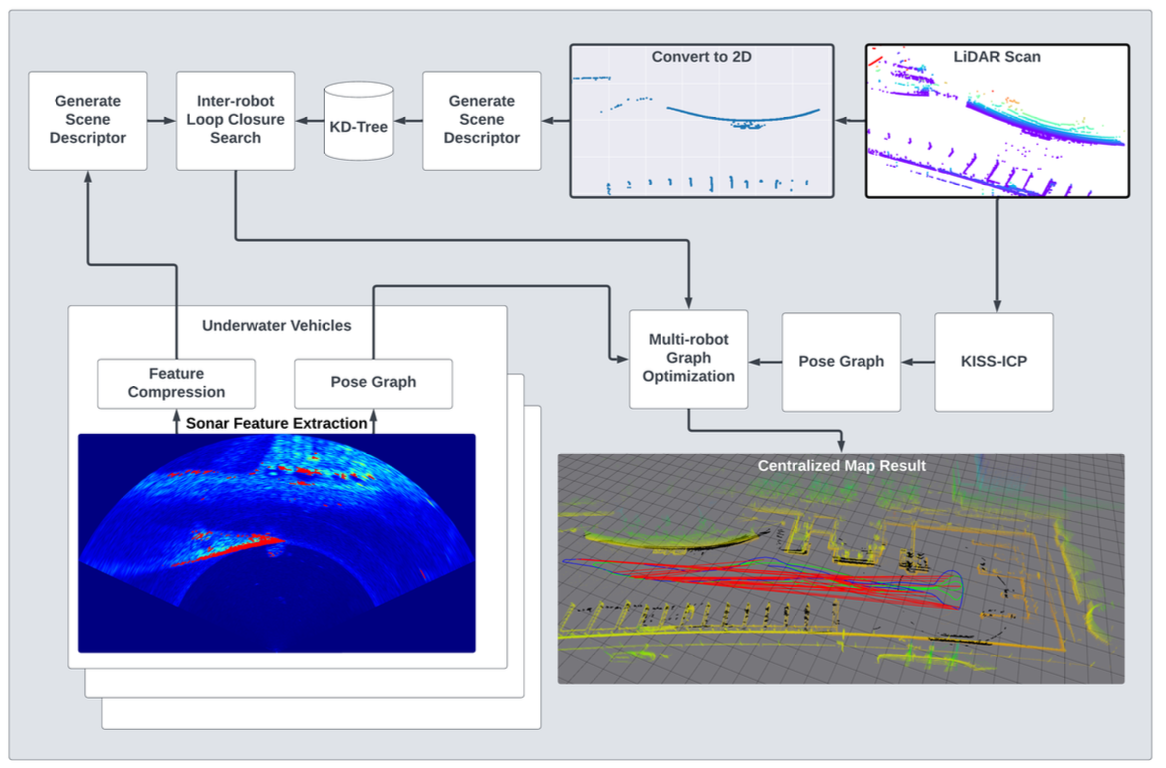
Above and Below: Heterogeneous Multi-Robot SLAM Across Surface and Underwater Domains RA-L
John McConnell, Armon Shariati, Paul Szenher, Yaxuan Li
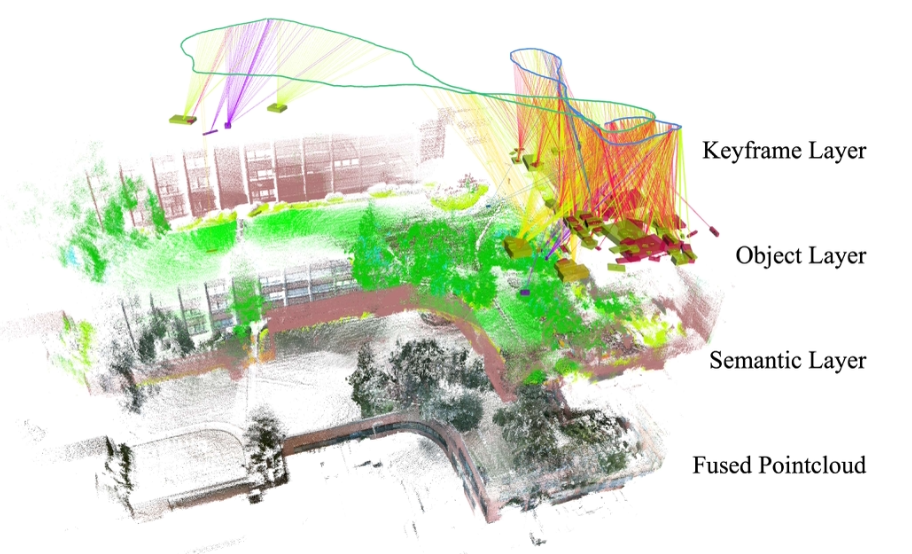
SGM-SLAM: Scene Graph Matching for Data-Efficient Distributed SLAM SSRR
Yewei Huang, Tixiao Shan, Abhinav Rajvanshi, Niluthpol Chowdhury Mithun, Yaxuan Li, Brendan Englot, Han-Pang Chiu
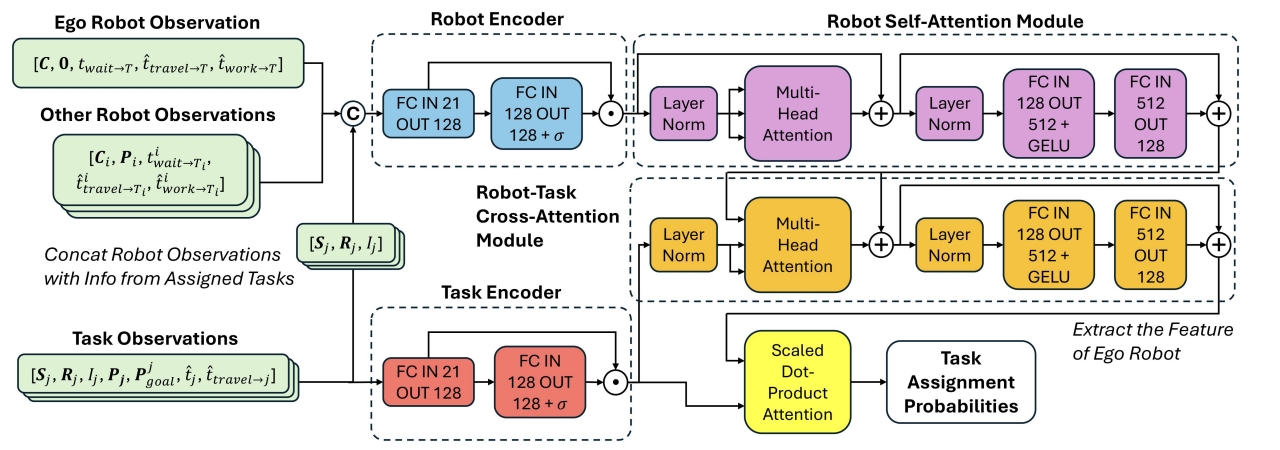
Reinforcement Learning Based Heterogeneous Task Allocation Under Spatio-Temporal Environmental Uncertainty for Multi-Robot Teams SSRR
Xi Lin, Yaxuan Li, Paul Szenher, Brendan Englot
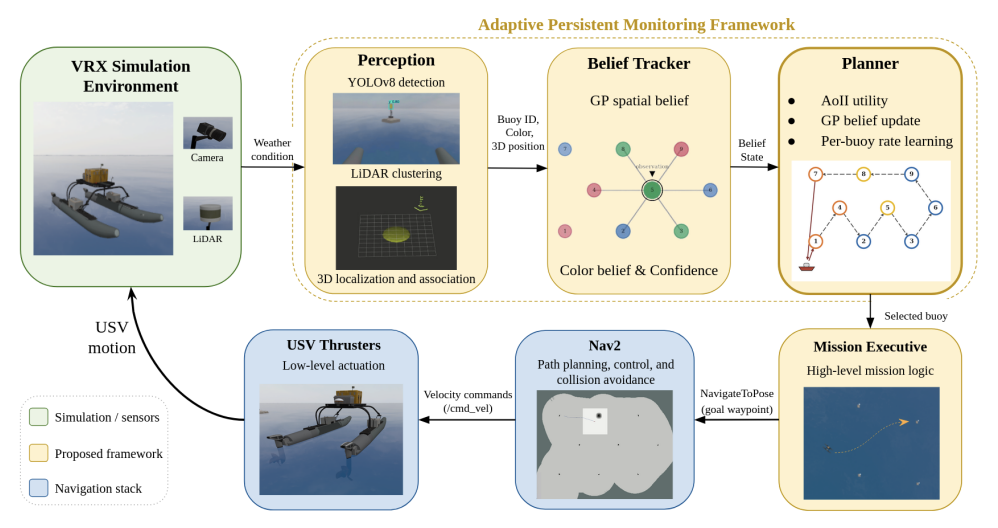
AoII-Based Persistent Monitoring for Unmanned Surface Vehicles in Spatiotemporal Fields SSRR
Razan Andigani, Yaxuan Li, Ivana Collado-Gonzalez, David Storch, Brendan Englot
Education
- 2023 – 2027 Ph.D. in Mechanical Engineering, Stevens Institute of Technology. Provost Doctoral Fellowship (2023–2024).
- 2021 – 2023 M.S. in Mechatronics and Robotics, New York University.
- 2016 – 2020 B.S. in Machinery Design, Manufacture and Its Automation, Qiushi Honors College, Tianjin University.